Autonomous Navigation Sandbox
A browser-based grid world for testing planning and waypoint following.
- A* planning
- Task state machine
- Unit-tested engine
Moonpie Robotics · A research division of Moonpie Software Labs
Exploring intelligent machines, embodied AI, and new ways for humans and technology to work together.
Status key
Every item on these pages carries its real status. Prototype and Validated exist in the system but are not used until evidence exists.
01Research
Moonpie Robotics is an emerging research initiative exploring the intersection of robotics, artificial intelligence and human–machine interaction.
How a machine perceives a space, decides where it can safely go, and moves through it — developed and tested in software long before it touches hardware.
Connecting perception, reasoning and physical action: AI judged by what it reliably and safely does in a space.
Early, non-invasive research into how people and machines can communicate — signal visualisation and accessibility, not medical devices.
02Concept platforms
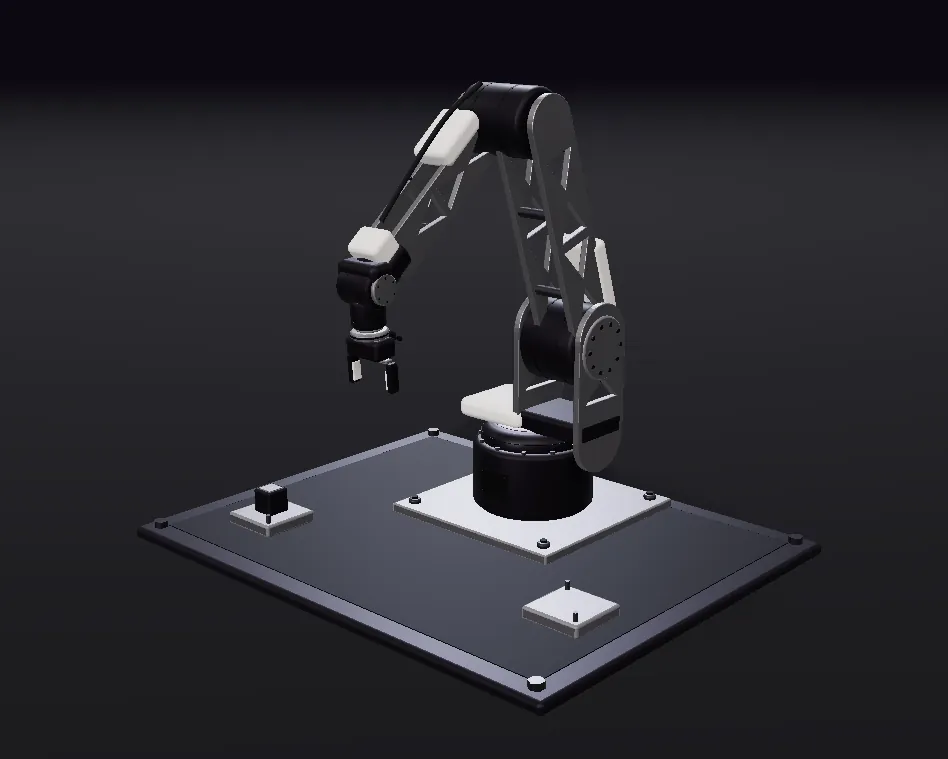
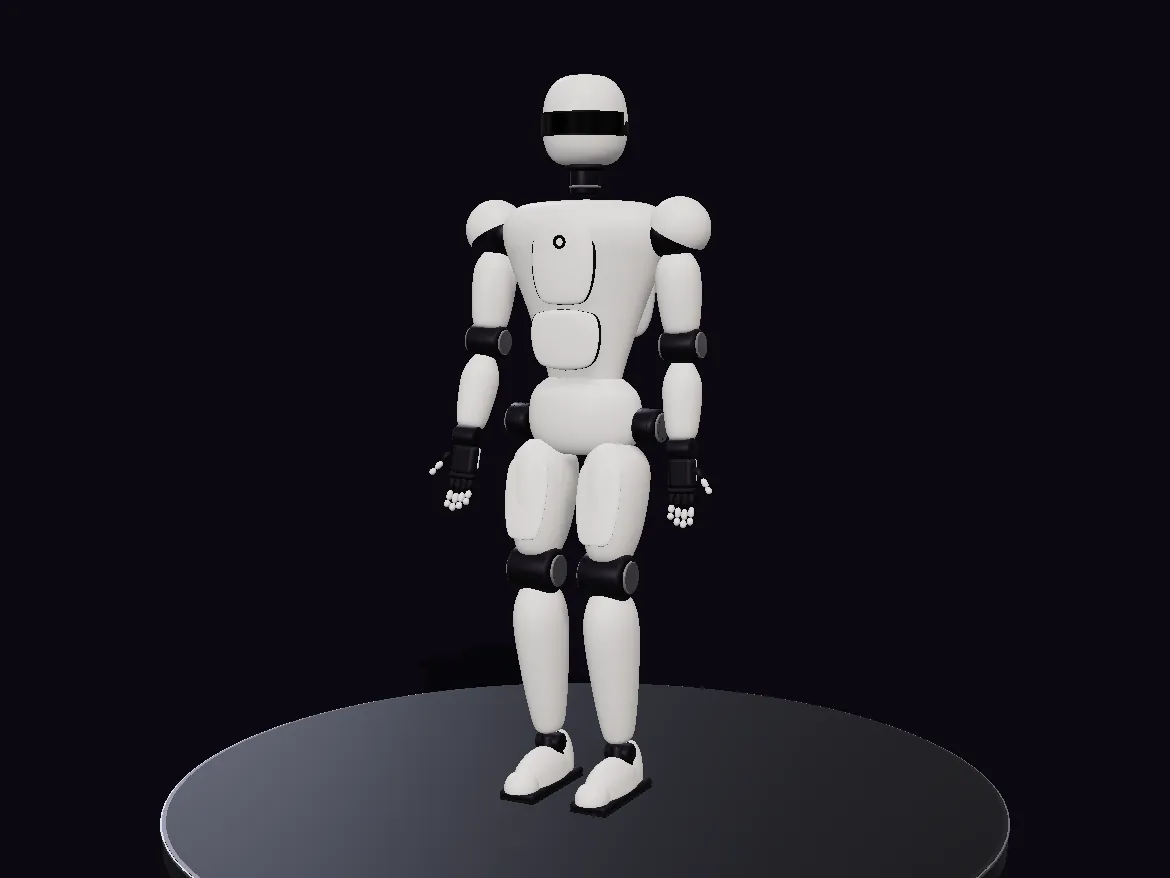
The research questions on this page are about real kinds of robot. These are Moonpie concept models of those kinds, engineered in code to one design language so the ideas have a credible shape. Pick one, turn it, and inspect its joints.
03Cinematic film
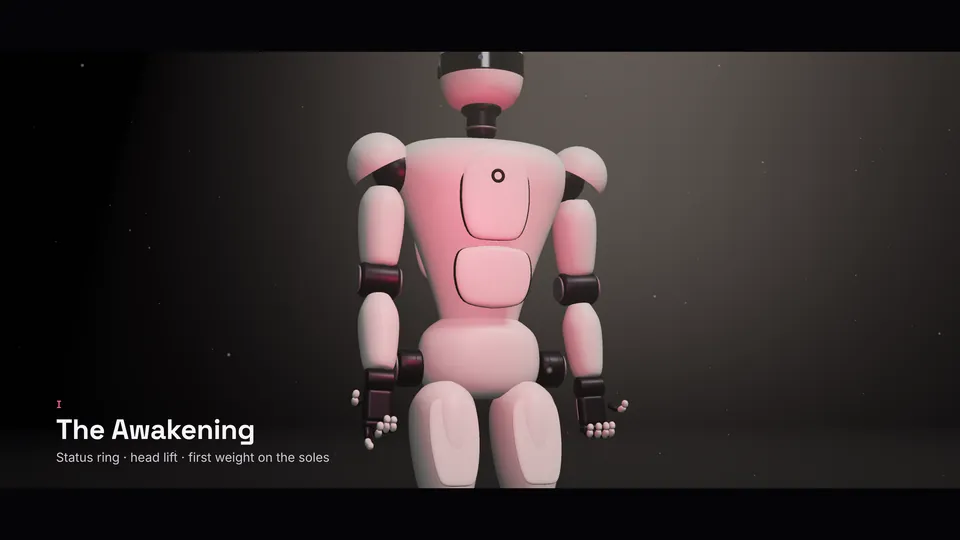
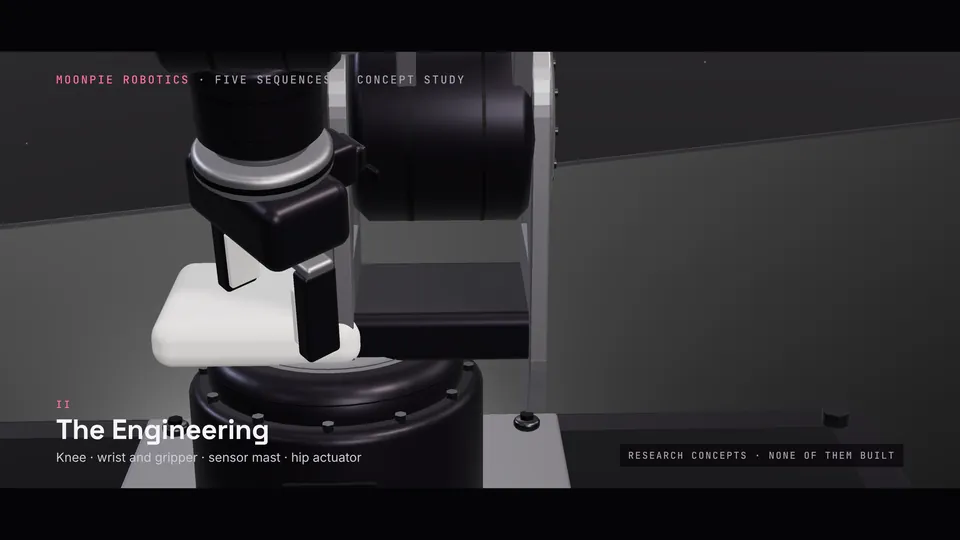
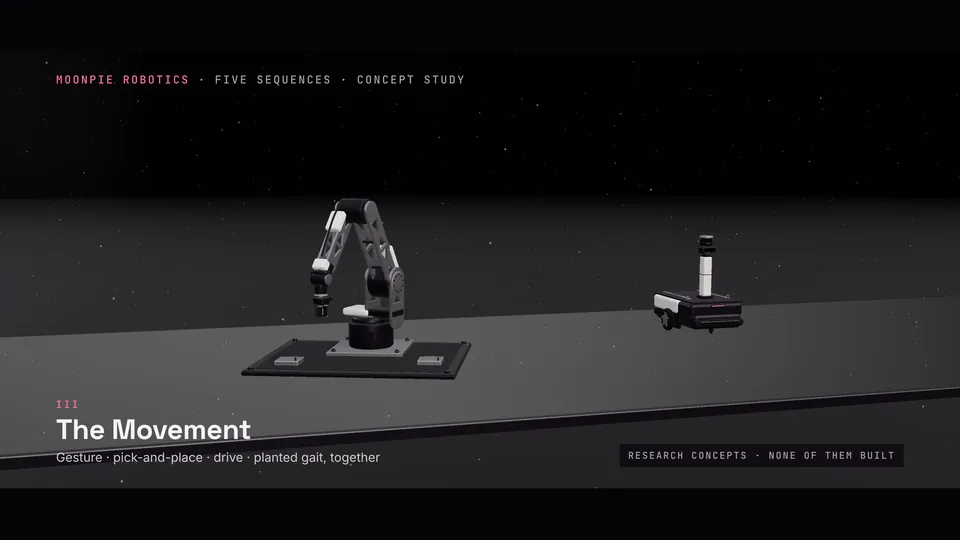
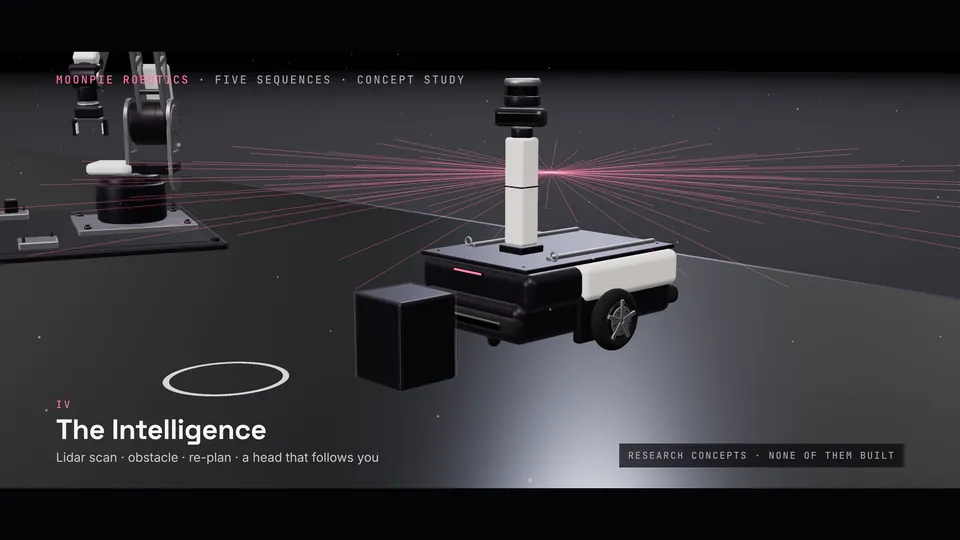
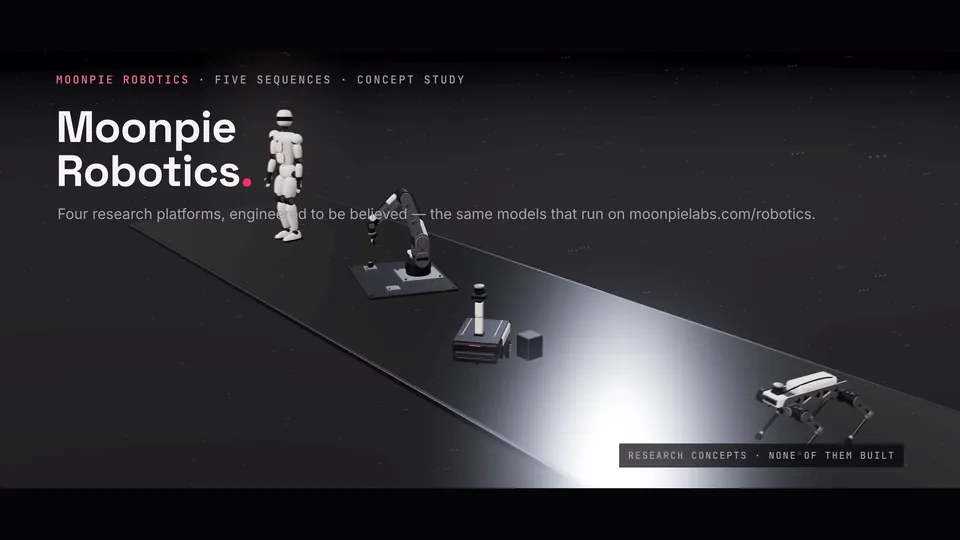
A 32-second cinematic cut of the concept fleet: the Companion wakes under a single shaft of light; macro passes over a knee, a wrist, a sensor mast and a hip; one tracking shot with all four moving; the Navigator's lidar detecting and re-planning while the Companion's head follows the camera; and an orbit to the reveal. Same models, same sequences as the showcase above, rendered from one kinematics source — now with depth of field, shutter accumulation, a lacquered stage and a score synthesised from the robots' own motion.
Still frame
04Navigation sandbox
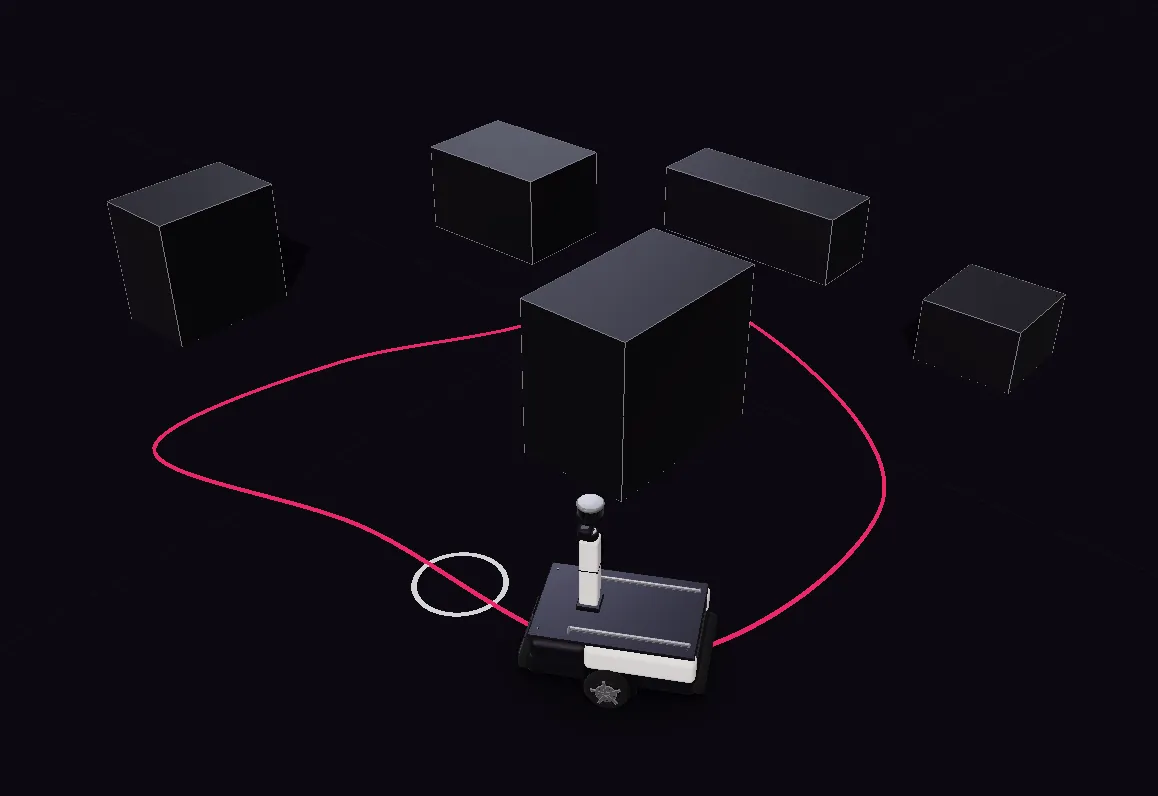
A differential-drive robot on a 16 × 10 occupancy grid plans a collision-free route with A* and follows it. It runs in your browser.
Simulation mode
05Projects
A browser-based grid world for testing planning and waypoint following.
Decomposing a plain-language instruction into ordered, checkable robot actions, with a human approving the plan before execution.
A planned visualisation tool for public, consented EEG datasets. No personal data is collected; no diagnostic claim is made.
A long-term programme on how people supervise, correct and trust machines — beginning with interface studies in simulation.
06Neurotechnology roadmap
Each stage depends on the one before it. Moving between stages requires evidence, ethics review and, where it applies, regulatory approval — none of which is assumed.
Research status
Still frame
07Method
Every behaviour is built and tested in software before any physical experiment is considered.
The same inputs give the same run, so a failure can be reproduced and studied.
A person can pause, stop or override, and plans are approved before they run.
Nothing is described as built until it is built.
07Partnerships and contact
Moonpie Robotics is at the beginning. If your work overlaps with ours, we would like to hear from you. Enquiries go to the Moonpie Software Labs team through the site's contact form.
Write to us